Veg, a drone that flies without GPS
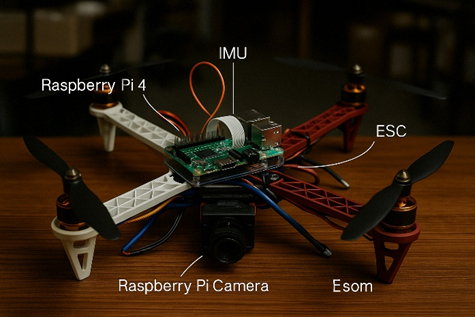
Veg means speed in Sanskrit. It is our research quadcopter for places where satellite positioning fails: inside buildings, under cover and in cluttered industrial sites.
Now: building Veg 3.0 in simulation
How Veg works
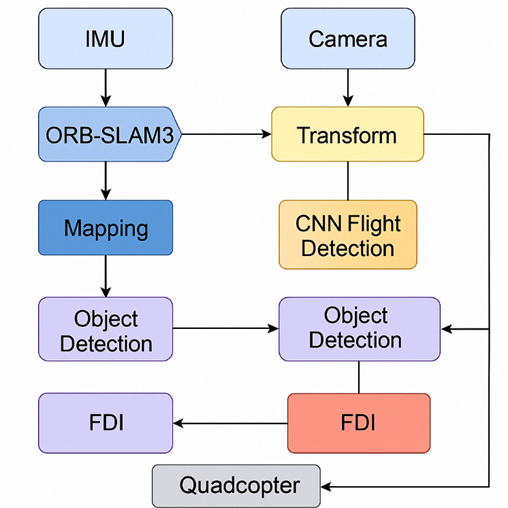
Veg runs four jobs at once, all onboard. A camera and an IMU feed ORB-SLAM3, which tracks the drone in six degrees of freedom and closes loops when it returns to a place it has seen. The map points become an occupancy grid, and a Dijkstra planner finds a route through it.
An Arduino Nano holds the drone steady with an LQR attitude controller while the Raspberry Pi 4 runs a position controller on top of the SLAM pose. A fault monitor watches the motors and the attitude response. When a rotor fails, Veg picks the nearest safe landing zone on its map and descends there.
A lightweight CNN detects people and vehicles, and a PCA model recognises known faces. Both run beside the control loop, never inside it, so heavy vision work cannot make the drone unstable.
Results from the paper
Simulation and lab results for the research version, as reported in our arXiv preprint.
- Attitude control
- LQR settles a 5° roll step in 0.1 s, against 3 s for the PID baseline
- Maze flight
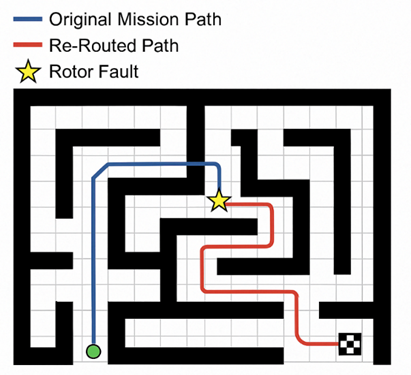
- 5 of 5 simulated runs reached the goal, average deviation under 0.35 m
- Rotor fault
- Detected in 1.3 s on average, safe landing in 8 of 10 simulated runs
- Object detection
- About 2 frames per second on the Pi CPU at 91.7% precision
- Face recognition
- 94.6% accuracy on a 20 person test set
- Electrical draw
- About 4.3 W for SLAM, vision, fault monitoring and control together
What comes next
Veg 3.0 is being built simulation first. We are building a full simulation of a SLAM based drone, and every part of the system is tested there, with faults injected on purpose, before it is trusted in the air. Hardware comes after the simulation proves the design.
If you want to follow the work, partner on a pilot or join the team, write to us.
Reading on Veg and aerial robotics
-
Veg Drone: SLAM-Based Surveillance Quadcopter with Onboard Vision and Fault Recovery
Meet Veg, a self-reliant quadcopter that flies without GPS, detects people and faces in real-time, and knows how to land safely even when a motor fails.
-
Aerial Robotics & Drones
How quadcopters fly and navigate without GPS: rotor layout, 6-DoF movement, UAV components and SLAM mapping explained step by step.