New in the world of SLAM
We build spatial intelligence for robots. Right now that means a SLAM based drone, built and tested in simulation first, so it can map, plan and fly where GPS cannot reach.
What we work on
Four areas, one goal: a robot that knows where it is and decides well what to do next.
SLAM and path planning
Visual and inertial mapping that keeps a robot localized indoors, underground and anywhere satellites drop out, with planners that turn the map into a safe route.
Deep learning
Perception that runs on the robot itself: detection and recognition today, and learned 3D models that make maps denser and tracking more reliable.
Reinforcement learning
Robots that learn decisions from experience, built on the math of Markov decision processes.
Robotics and robot learning
Robots that learn skills by watching people, and the hardware and control that let them act on what they learn.
Veg, our drone that flies without GPS
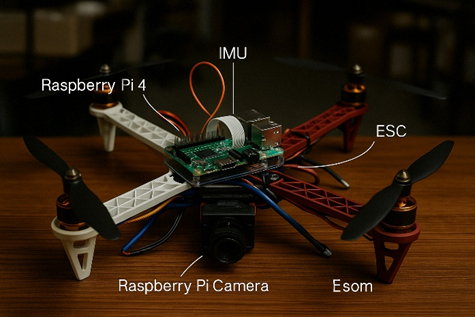
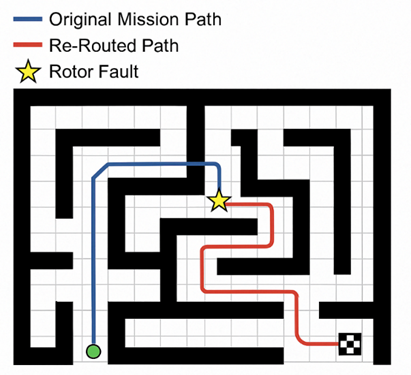
Veg maps its surroundings with visual inertial SLAM, plans its own route, recognises people and objects onboard and lands safely after a rotor failure. The research version runs entirely on a Raspberry Pi 4 and an Arduino Nano, and is described in a paper on arXiv.
- Localization
- ORB-SLAM3, monocular and inertial
- Planning
- Dijkstra over a map built from SLAM points
- Control
- LQR attitude loop, PD position loop
- Safety
- Rotor fault detection with rerouted landing
- Vision
- Onboard object detection and face recognition
Now: building Veg 3.0 in simulation
Latest research
-
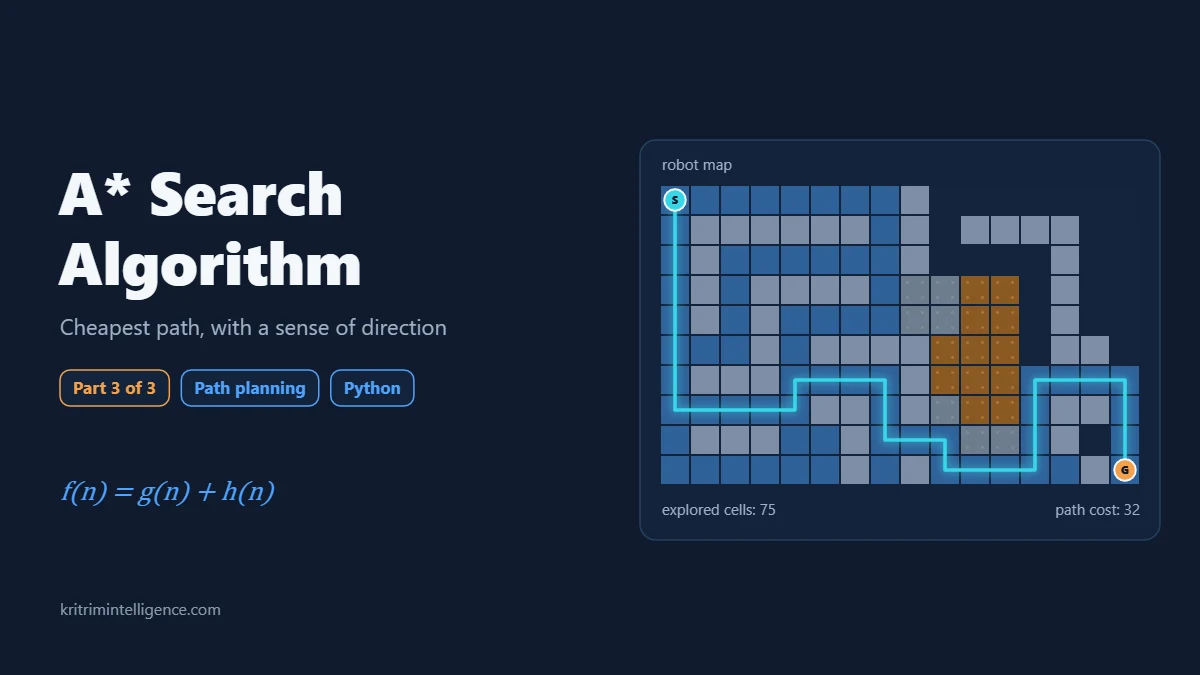
A* Search Algorithm Explained: f = g + h, Heuristics and Python Code
A* search explained: how f = g + h works, admissible heuristics, weighted A*, a tested Python example and a TurtleBot3 running A* in ROS 2.
-
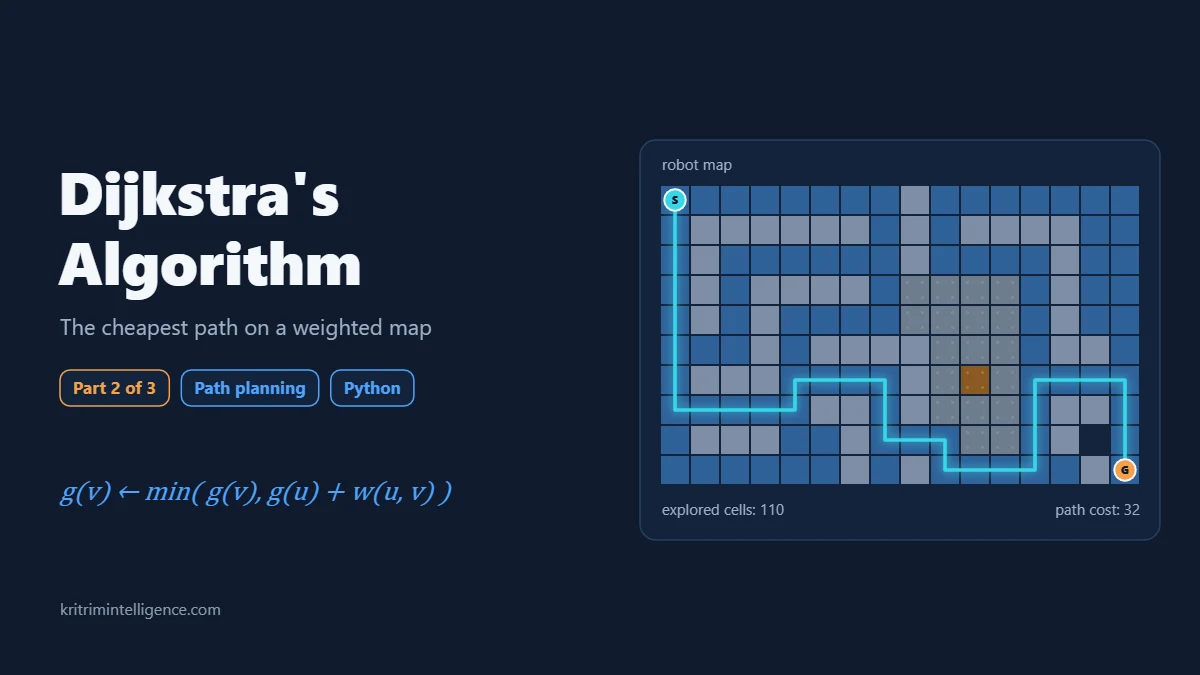
Dijkstra's Algorithm Explained: Cheapest Paths for Robots, with Python Code
Dijkstra's algorithm explained step by step: priority queues, edge relaxation, why it finds the cheapest path, and a tested Python example on a robot grid map.
-
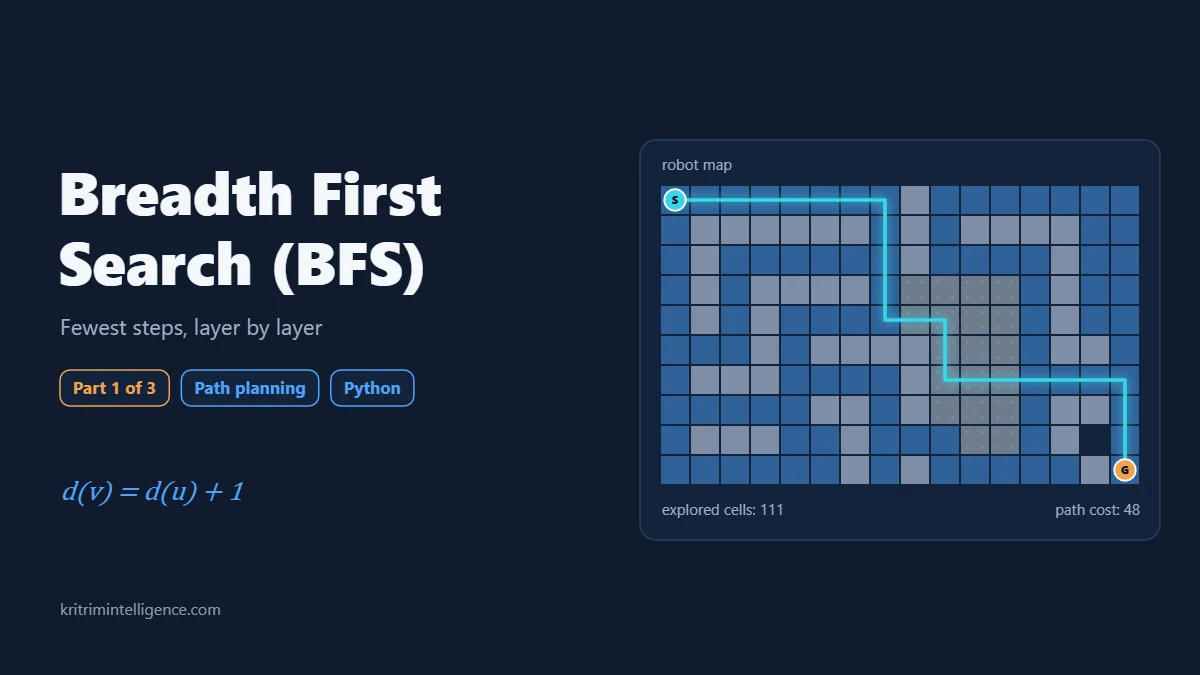
Breadth First Search (BFS) Explained: Shortest Paths for Robots, with Python Code
Breadth first search explained from the ground up: how the queue works, why BFS finds the fewest steps path, and a tested Python example on a robot grid map.
-
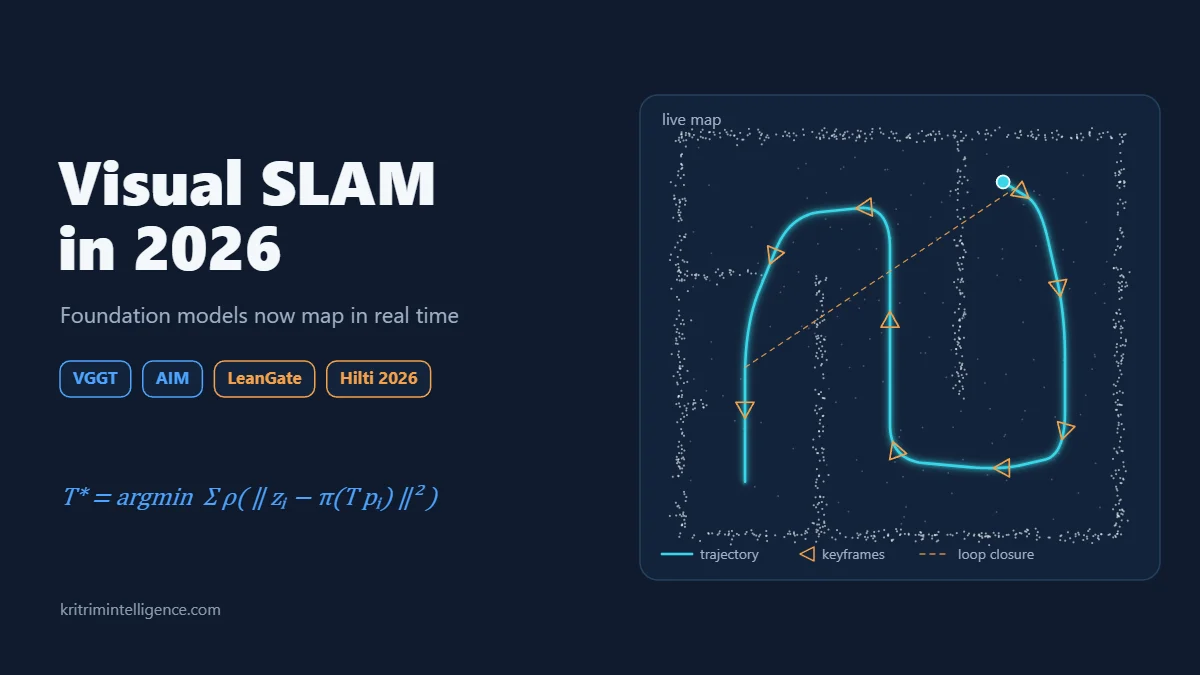
Visual SLAM in 2026: Foundation Models Now Map in Real Time
The biggest visual SLAM updates of 2026: VGGT-SLAM 2.0, AIM-SLAM, LeanGate and the Hilti Trimble challenge, and what they mean for drones that fly without GPS.
-
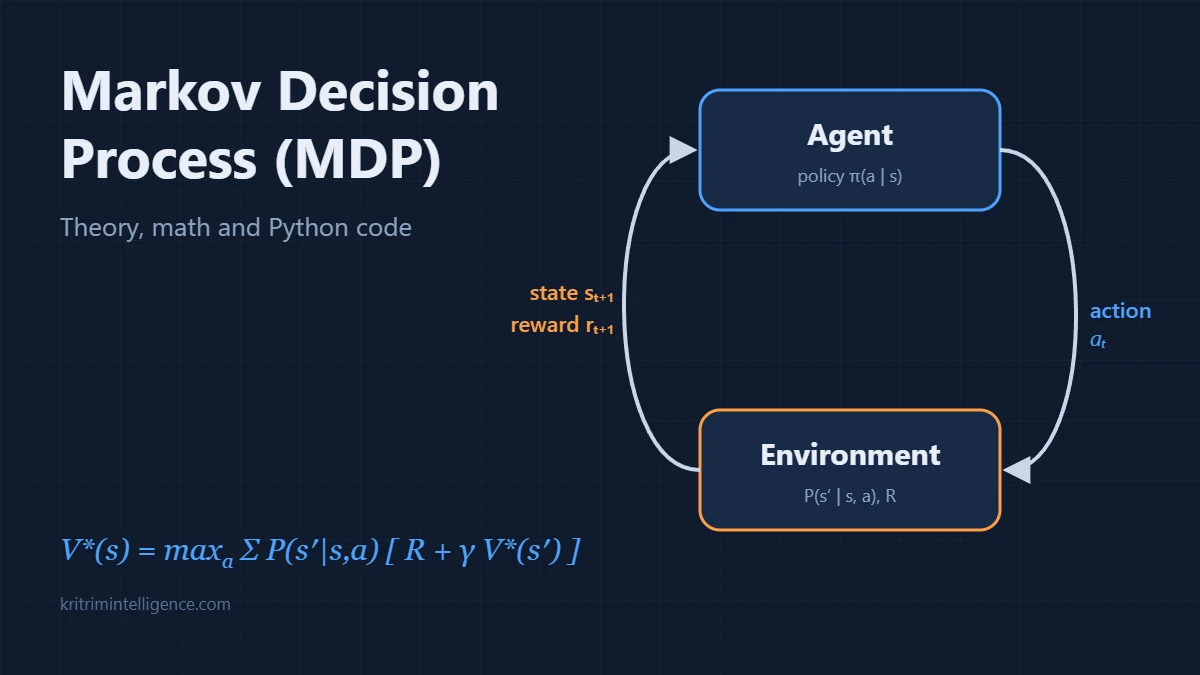
Markov Decision Process (MDP) Explained: Theory, Math and Python Code
Learn Markov decision processes step by step: the Markov property, Bellman equations, value iteration and policy iteration, with a full Python grid world example.
Build with us
We are looking for research partners, pilot customers and engineers who want robots that work without GPS.